
 Internal Vibrator
 External Vibrator
 Submersible Pump
 Eccentric shaft
 Pendulum shaft
 Portable vbrator shaft
 Portable concrete mixer
 Vertical concrete mixer
 Hydraulic concrete mixer
 Walk behind power trowel
 Ride on power trowel
 Concrete screed
 Tamping rammer
 Plate compactor
 Vibratory roller


Control Lever Ergonomics and Operator Precision: The Human-Factor Engineering of Walk-Behind Tamping Rammers in Confined Construction Corridors
Why Tamping Rammers Work Best in Confined Corridors
In modern civil engineering, compacting soil in confined utility corridors presents a distinct set of challenges. The task frequently involves consolidating disturbed earth within narrow trenches where heavy ride-on machinery cannot operate. The solution requires equipment capable of delivering high-intensity, directed energy without lateral spread that could damage adjacent infrastructure. To address this, contractors rely on thetamping rammer, a hand-held compaction device that applies vertical impact to the ground via a spring-loaded shoe moving in rapid reciprocating motion. This mechanical design ensures that energy is directed downward in concentrated pulses, making it uniquely suited for confined spaces.
To understand why this equipment excels, it is necessary to evaluate both its mechanical principles and its operational specifications. The design of these machines integrates precise ergonomics with raw kinetic output. The specific footprint of these machines, combined with their control structures, dictates the pressure distribution per unit area and allows operators to navigate tight trench boxes with minimal fatigue. By analyzing these factors, project managers can optimize their approach to trench reinstatement.
Compaction challenges in narrow trenches
The primary compaction challenge in narrow trenches stems from the physical constraints of the environment. Utility trenches, culvert sides, and bridge abutment backfills often provide less than a meter of working width. In these confined corridors, cohesive soils such as clay and loam must be consolidated to prevent future subsidence, which could otherwise compromise buried pipelines and surface pavements. The objective is to achieve high soil density in deep lifts within a footprint that restricts equipment movement and amplifies operator fatigue. Furthermore, operators must navigate the severe risks of striking buried utilities, requiring strict depth control and situational awareness. Critical operational limitations also apply: rammers are incompatible with saturated cohesive soils, which yield rather than compact, and their intense vibration poses a risk of trench wall collapse in unsupported excavations.
Tamping rammers vs vibratory plate compactors
When comparing tamping rammers to Vibratory Plate Compactors, the mechanical approaches diverge significantly. A vibratory plate utilizeseccentric weights to generate high-frequency, low-amplitude vibrations, which are highly effective at settling granular soils like sand and gravel over large, shallow areas. In contrast, the tamping rammer utilizes a percussion mechanism to overcome soil resistance and particle friction in cohesive soils, reducing air voids and forcing particles together into a dense matrix. Contractors can apply a concise decision logic for equipment selection: if the trench width is less than 60 cm and the soil plasticity index indicates cohesive clay or silt, specify a tamping rammer. If the area is open and the material is granular, a vibratory plate is required.
| Feature | Tamping Rammer | Vibratory Plate Compactor |
|---|---|---|
| Primary Soil Target | Cohesive (Clay, Silt, Loam) | Granular (Sand, Gravel, Asphalt) |
| Compaction Action | High-amplitude vertical impact | High-frequency surface vibration |
| Space Suitability | Highly effective for narrow trenches | Optimal for open, wide surfaces |
Control lever design and operator handling
The effectiveness of a rammer in these tight spaces relies heavily on its control lever design and operator handling. The control lever serves as the primary interactive interface, and its ergonomic geometry directly affects biomechanical alignment. A properly designed handle allows the operator to maintain an upright posture, reducing lower back strain and steering fatigue during prolonged trench navigation. Advanced grip damping and vibration isolators are engineered to minimize the transfer of kinetic energy to the operator's hands. However, it is a misconception that isolators universally keep exposure below the standard action value of 2.5 m/s² A(8). In reality, handle vibration magnitude must be actively measured and managed against daily trigger-time limits to mitigate the risk of hand-arm vibration syndrome (HAVS). Additionally, modern battery-electric units often feature different weight distributions than their combustion counterparts, altering the machine's center of gravity and requiring operators to adjust their handling techniques. Mandatory personal protective equipment (PPE), including hearing protection and steel-toed boots, remains required during operation to ensure safety over long shifts.
How the Robin EY20 Engine Affects Rammer Performance
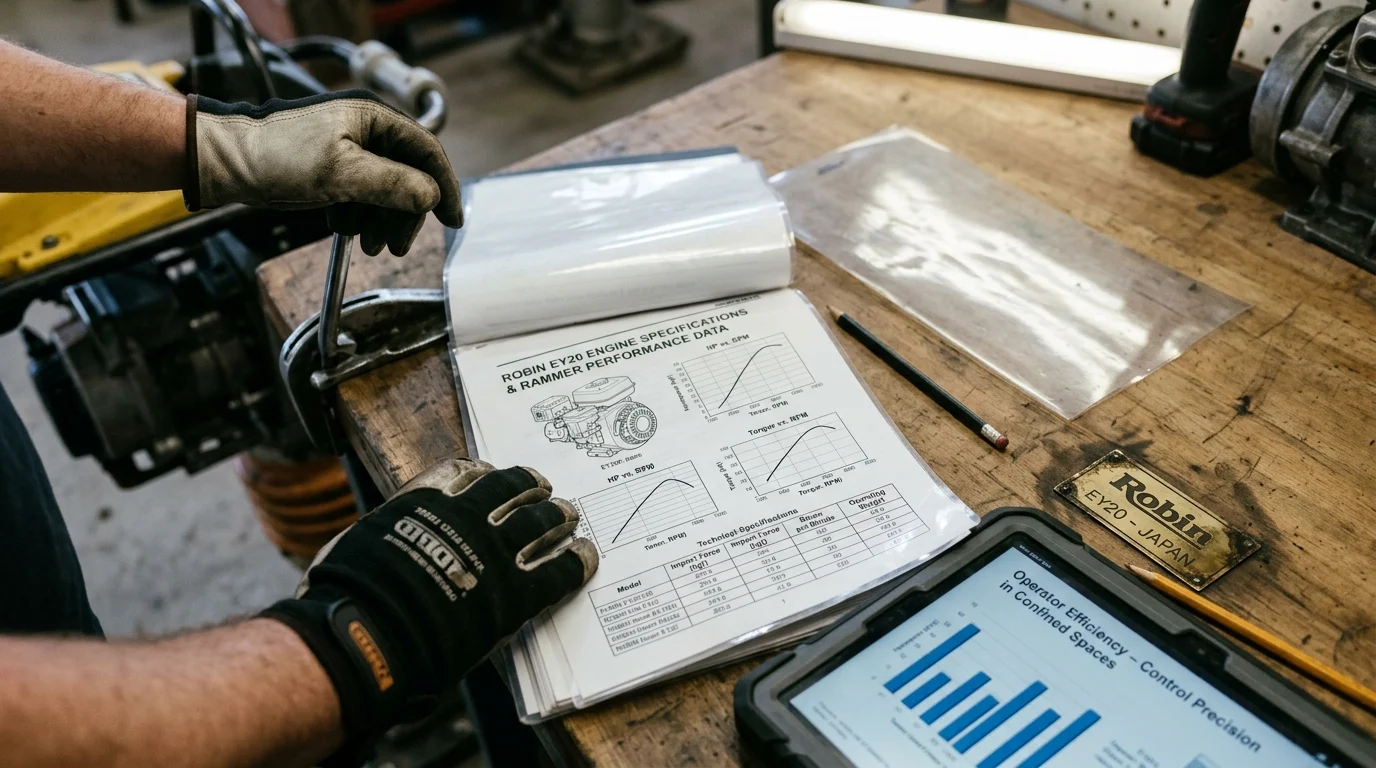
The prime mover of any compaction equipment dictates its operational threshold, presenting a unique challenge: the engine must survive extreme, continuous shock loads that would quickly destroy standard commercial motors. For heavy-duty rammers, the mechanical architecture relies on specialized internal combustion designs to isolate the carburetor and ignition systems from the reciprocating motion of the chassis. While modern fleets predominantly utilize advanced engines like the Honda GX series (e.g., GX100/GX120) or emission-free battery-electric drives, the historical baseline for this demanding application was established by the Robin EY20 engine, a power plant specifically modified for high-vibration environments.
Evaluating this legacy prime mover provides insight into the foundational specifications of the industry. The EY20 established the standard for continuous jobsite uptime, proving that a reliable, sustained torque curve is essential to ensure the rammer's impact mechanism cycles flawlessly through dense, cohesive soils without stalling.
Key Robin EY20 specifications
The key Robin EY20 specifications established the baseline for the machine's kinetic potential. As an air-cooled, 4-stroke, single-cylinder engine, it maximized fuel atomization and combustion efficiency for its era. Its horizontal PTO (Power Take-Off) shaft was critical, interfacing directly with the rammer's centrifugal clutch and crank gear system to translate rotary motion into vertical thrust. By maintaining a continuous output of 2.61 kW at 3600 rpm, the 183 cc engine guaranteed that the eccentric gear mechanism received a steady influx of kinetic energy, preventing rpm drop during ground contact. Rather than focusing solely on these legacy numbers, modern procurement now uses these historical benchmarks to evaluate current prime-mover selection criteria, ensuring new engines deliver equivalent or superior torque and durability.
Gasoline power for jobsite flexibility
Gasoline power provides distinct jobsite flexibility compared to alternative fuel sources. While diesel engines offer higher low-end torque and superior fuel economy for massive, slow-moving equipment, they are inherently heavier and more difficult to start in cold ambient temperatures. In the context of a walk-behind rammer, gasoline-powered engines present a lighter, more user-friendly profile. This weight reduction is crucial for maintaining the machine's center of gravity and ensuring the operator can easily maneuver the equipment within narrow trench boxes. Today, this flexibility is further expanded by electric drives, though gasoline remains prevalent for remote sites without charging infrastructure.
Engine weight, starting, noise, and torque
When analyzing engine weight, starting reliability, noise, and torque, legacy engines demonstrated a balanced performance profile that modern power plants have since refined. Recoil starters are optimized for immediate ignition, reducing operator fatigue before work begins. Furthermore, the 4-stroke architecture inherently produces lower operating noise compared to equivalent diesel models, a critical compliance factor in residential municipal repairs. The torque generated at 3600 rpm is precisely matched to the resistance of the clutch springs, ensuring immediate engagement. The specific continuous output of this engine class addresses the need for prime-mover durability, providing the reliable torque necessary to drive the rammer's high-impact compaction cycle.
How Tamping Rammers Deliver Deep Soil Compaction
Achieving deep soil consolidation requires overcoming a fundamental geotechnical challenge: cohesive soils, such as clay and silt, possess strong intermolecular bonds and air voids that resist static pressure. To overcome this resistance, the tamping rammer relies on a pulse-driven impact mechanism. Rather than pressing the soil, the machine delivers high-impact blows that force air out of the soil matrix, allowing the particles to realign into a dense, load-bearing structure.
The specifications of this mechanism define its capability. Because the frequency and jump height determine the compaction energy delivered per unit time, these machines can effectively influence deep cohesive soil layers. However, as a critical operational caveat, achieving optimal density requires compacting the soil in multiple controlled lifts of 15-20 cm (6-8 in) each. Exceeding this maximum safe lift thickness risks bridging and inadequate lower-level compaction, while over-compaction can break down soil structure and damage adjacent utilities.
Pulse-driven impact mechanism
The pulse-driven impact mechanism is a highly efficient system of kinetic conversion. The mechanical process involves the engine's horizontal PTO shaft spinning a crank gear, which drives a connecting rod up and down. This reciprocating motion is transferred to a heavy-duty spring cylinder. The springs absorb the downward stroke and release it explosively, driving the rammer shoe into the soil. This mechanism converts continuous rotary power into discrete, high-amplitude vertical pulses, ensuring maximum energy transfer into the trench floor.
Impact and vibration in soil densification
The combination of impact and vibration is what drives deep soil densification. While the primary vertical impact breaks the soil's natural cohesion, the secondary vibration acts to fluidize the soil particles momentarily, allowing them to slide into a tighter matrix. The jump height ensures that the shoe lifts high enough to generate sufficient terminal velocity before striking the ground. This dual action is why rammers are vastly superior to static rollers in mixed and semi-cohesive materials.
Soil checks before compaction
Before initiating this aggressive compaction process, rigorous soil checks must be conducted. Operators must evaluate the moisture content of the cohesive soil; if it is too dry, the soil will fracture into dust. Conversely, excessive moisture causes the soil to pump and yield like a liquid, severely reducing compaction efficiency—a key reason rammers are incompatible with saturated soils. When the moisture is at the optimum level, the rammer's force can reliably achieve the targeted density. Ultimately, the precise calibration of impact frequency and jump height overcomes cohesive soil resistance, yielding an optimal compaction energy per unit time that ensures long-term foundation stability.
Key Performance Parameters for Walk-Behind Tamping Rammers
To properly deploy equipment on a jobsite, contractors face the task of matching machine kinematics to specific geotechnical requirements. Effective compaction relies on the interplay of mass, velocity, and surface area. Contractors cannot simply look at a machine's engine; they must evaluate the entire kinematic system to understand how kinetic energy is distributed into the ground.
This system is quantified through core performance parameters. The operating weight determines the impact inertia, while the shoe size determines the pressure distribution per unit area. Together, these parameters allow the operator to achieve rapid, uniform soil densification without over-compacting or displacing the material.
Operating weight, speed, and impact force
The relationship between operating weight, advance speed, and impact force dictates the machine's efficiency. A heavy-duty unit possesses substantial mass, and the underlying principle is that greater mass yields greater impact inertia, preventing the machine from simply bouncing off hard soils. When this mass is driven downward, it generates a deep stress bulb in the soil. The advance speed ensures that the operator can cover ground efficiently while allowing the machine to deliver sufficient blows per square meter to reach the required Proctor density. (Refer to the specification table below for standard operational ranges).
Shoe size and compaction precision
Shoe size and compaction precision are intrinsically linked. Standard shoe dimensions are engineered to balance penetration with stability. If the shoe were smaller, it would punch through the soil like a needle, causing lateral displacement rather than vertical consolidation. If it were larger, the impact force would be spread too thin, reducing the pressure per unit area and failing to compact deep lifts. For an example of how these specifications are integrated into modern equipment, refer to a standard Tamping Rammer. The shoe's footprint is scaled to fit inside standard trench boxes while maximizing the downward pressure gradient.
Specification-to-application comparison
A specification-to-application comparison reveals how these parameters translate to field success. The following table consolidates the core technical specifications required for effective equipment selection:
| Parameter | Standard Specification Range | Practical Engineering Value |
|---|---|---|
| Operating Weight | 60-90 kg (132-198 lbs) | Determines downward impact inertia and resists bounce. |
| Impact Force | 10-18 kN (2248-4046 lbf) | Breaks natural soil cohesion to eliminate air voids. |
| Advance Speed | 10-15 m/min (32.8-49.2 ft/min) | Dictates project timeline and blows per square meter. |
| Jump Height (Stroke) | 40-65 mm (1.57-2.55 in) | Defines the kinetic strike velocity before ground contact. |
| Impact Frequency | 450-650 blows per minute | Fluidizes soil particles for tighter matrix alignment. |
| Shoe Size | 250x280 to 300x330 mm | Determines pressure distribution per unit area. |
| Effective Depth | 50-60 cm (19.7-23.6 in) | Maximum consolidation depth (achieved via 15-20 cm lifts). |
By understanding these metrics, project managers can accurately forecast compaction rates. Carefully balancing operating weight for inertia and shoe size for pressure distribution ensures precise, efficient compaction in diverse cohesive soils.
How Contractors Should Specify Tamping Rammers
Procuring the right equipment involves securing a fleet asset that maximizes return on investment while meeting stringent municipal compaction codes. Procurement should focus on ensuring that the machine's mechanical thresholds align directly with the daily operational realities of trench backfill, foundation preparation, and asphalt patching. A mismatch between equipment specs and field applications leads to structural failures and costly rework.
To mitigate this risk, procurement relies on concrete performance data and quality assurance metrics. Contractors should specify machines capable of meeting the effective depth requirements outlined in the performance parameters, backed by rigorous factory performance testing and a comprehensive warranty covering core components like the engine, impact mechanism, and spring system. These procurement standards result in an optimized total cost of ownership (TCO) and minimized downtime, ensuring that operators can maintain consistent operational processes day in and day out.
Matching specifications to trench backfill tasks
Matching specifications to trench backfill tasks is the first step in successful deployment. When laying pipe, the backfill must protect the utility from future soil shifting without damaging the infrastructure during the compaction process. Specifying an appropriately sized rammer ensures that the machine fits beside the pipe without striking it, while delivering the necessary force to consolidate the lift. Contractors must evaluate the typical width of their excavations; the narrow body design of these rammers makes them indispensable for roadside repairs and culvert work where vibratory plates simply cannot fit or function properly.
Operating process for consistent compaction
Establishing a standardized operating process is critical for consistent compaction. The control of the machine relies heavily on the operator's technique and adherence to safety protocols. Operators must be trained to guide the machine rather than muscle it, maintaining a posture that leverages the equipment's forward momentum. By allowing the machine's advance speed to dictate the pace and strictly adhering to maximum lift guidelines, the operator ensures an even distribution of the blows. This consistent overlap prevents soft spots in the trench that could lead to future pavement failure.
Warranty, testing, and equipment reliability
Finally, warranty, testing, and equipment reliability form the backbone of fleet management. Because a tamping rammer is essentially a machine designed to subject itself to continuous high-impact blows, component fatigue is inevitable. Specifying equipment where every unit undergoes factory performance testing prior to shipment mitigates out-of-the-box failures. Furthermore, securing a robust warranty on the prime mover and the kinetic spring system protects the contractor's capital investment. Specifying a rammer with proven performance data and robust warranty backing ensures fleet reliability, yielding long-term operational stability and lowered holding costs.
Further reading:
Key Takeaways
- Specify a tamping rammer when trench width is under 60 cm and the backfill contains cohesive clay, silt, or loam.
- Use a vibratory plate compactor instead of a rammer for open areas with granular materials such as sand, gravel, or asphalt.
- Check soil moisture before compaction because saturated cohesive soil will yield under impact rather than densify effectively.
- Prioritize ergonomic control levers and manageable machine weight to improve operator precision and reduce fatigue in confined corridors.
- Confirm buried utility locations and trench support conditions before ramming to reduce the risk of infrastructure damage or wall collapse.
Frequently Asked Questions
When should a contractor choose a tamping rammer over a plate compactor?
Choose a tamping rammer for narrow trenches, especially under 60 cm wide, and for cohesive soils such as clay, silt, or loam. Use a vibratory plate compactor for wider areas with granular materials like sand, gravel, or asphalt.
Why are tamping rammers effective in confined construction corridors?
Tamping rammers deliver concentrated vertical impact through a small shoe, allowing deep compaction in tight spaces where ride-on equipment or wide plate compactors cannot maneuver safely or efficiently.
What role does control lever ergonomics play in operator precision?
Well-positioned control levers help operators maintain balance, adjust movement quickly, and reduce fatigue. In narrow trenches, this improves directional control and lowers the risk of striking utilities or trench walls.
Are tamping rammers suitable for saturated cohesive soils?
No. Saturated cohesive soils tend to deform or pump under impact instead of compacting properly. Moisture condition should be checked before compaction to avoid poor density results and rework.
Can tamping rammers be used near buried utilities?
Yes, but only with careful depth control, utility location, and trained operation. Their strong vertical impact is useful in trenches, but operators must avoid direct contact with pipes, conduits, and unsupported trench edges.